Trajectory Planner for Autonomous Ground Vehicles in Unknown Environments
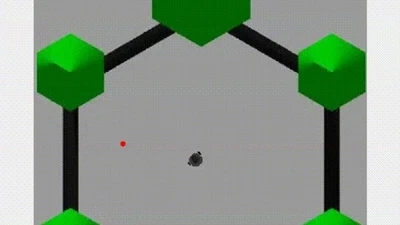
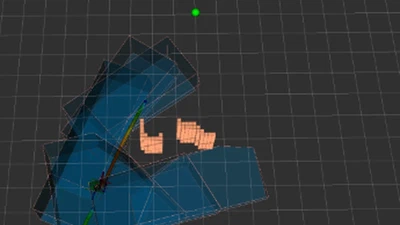
Master's thesis: a Hybrid A*/JPS trajectory planner with a novel free-space-estimation recovery behavior and MPC feedback control, extending the FASTER planning framework for …
•
1 min read