The Firefly: Autonomous Greenhouse Drone
Jul 13, 2024
·
1 min read
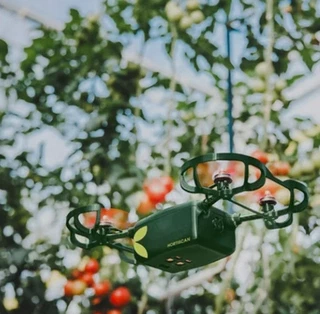
Core member in developing different software modules for an autonomous drone including: Control, trajectory planner, State estimation.
Key Contributions:
- State Estimation: Integrated different open-source state estimation modules, choosing the best one for the application based on pre-determined performance metrics
- Sensor Fusion: Fused LiDAR, VIO, and IMU data streams into the height estimation pipelines, advancing the system from research prototype to commercial deployment.
- Embedded Systems: Optimized navigation algorithms for real-time performance on resource-constrained platforms, leveraging embedded Linux and ROS2.
- Hardware Assembly: Participated in sensor calibration and initial setup, writing documentation to standardize these procedures.
Software Used: Ros 1 & 2, C++, Python, Autopilot Firmware, Docker, SkiffOS, Linux, Bash, Gazebo, Rviz, Git, OptiTrack, FoxgLove
Sample Result:
This video shows the full drone’s mission including takeoff, flying, and landing back to the charging station.

Authors
Senior Software Engineer
Software Engineer with 3 years of experience developing perception and autonomy systems for
UAVs operating in GPS-denied environments. Strong background in deep learning (PyTorch), reinforcement learning, and real-time C++/Python systems deployed on embedded edge platforms. My
expertise lies in translating complex research results into robust, production-ready software solutions.